CAD Modeling
3D Printing
Arduino IDE
Python
Controls
3D Rendering
Project Overview
Serving as my introduction to robotics design, this project involved designing a 4-DOF robotic manipulator. The 3 main parts of the project were:
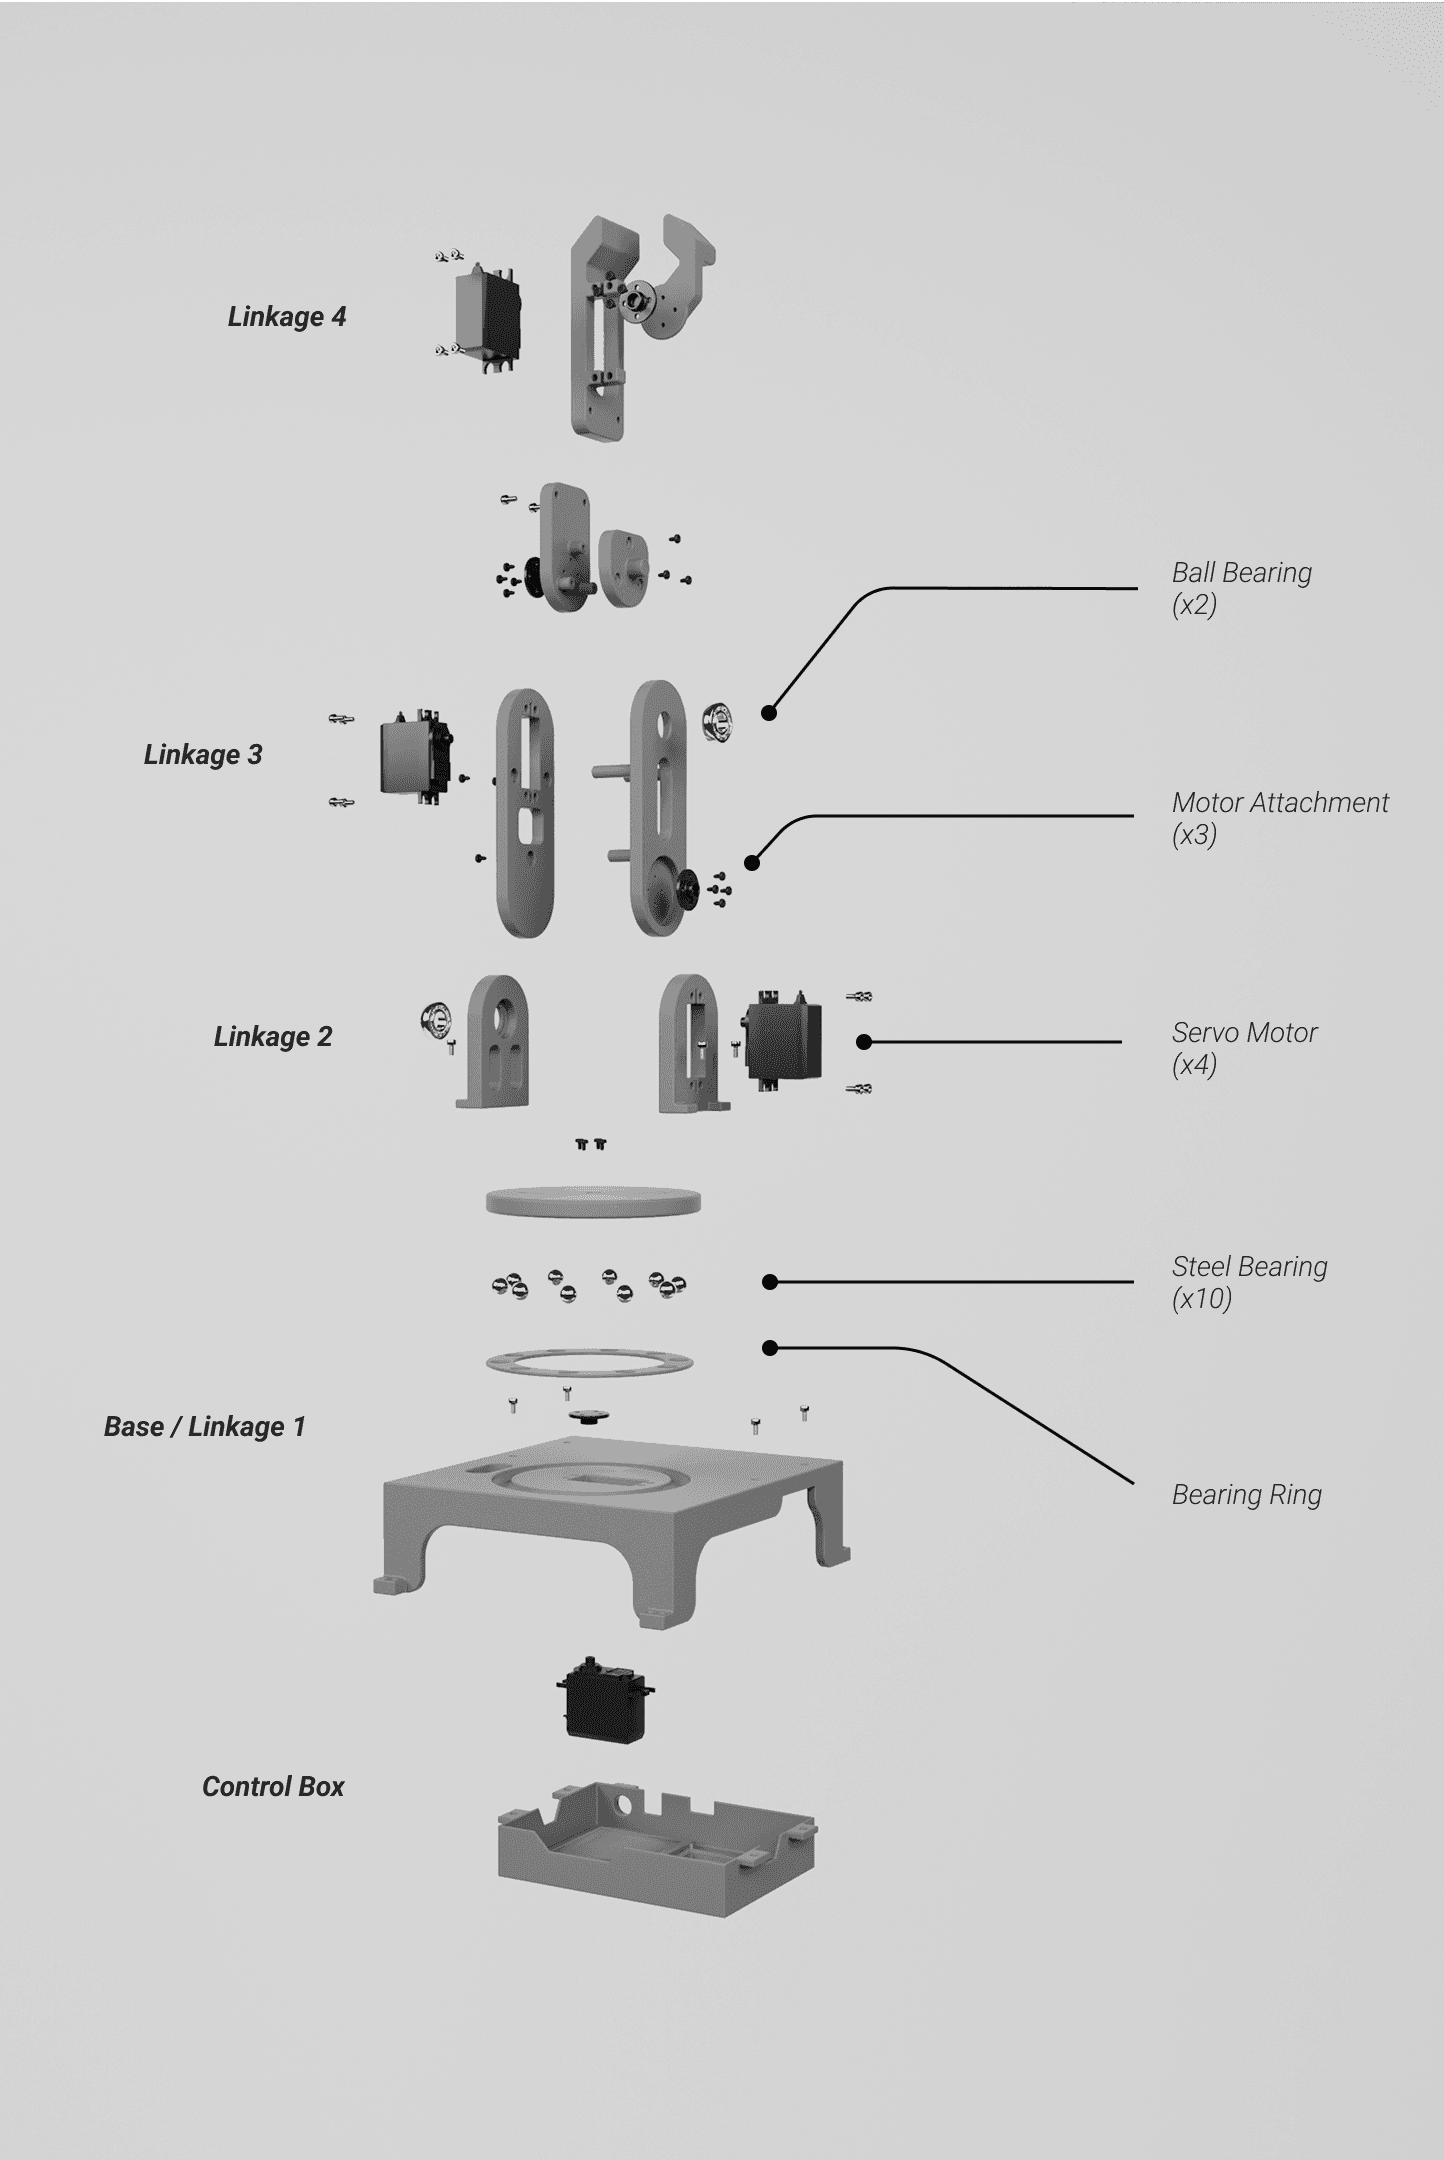
CAD assembly
Firmware for robot with Arduino IDE and Python
Fabrication and assembly of robot
I enhanced my previous knowledge in physical design by learning how combine CAD design with 3D printing and a programmable microcontroller. I also learned the basics of Arduino IDE to code the firmware for the robot.
final design


User input can be received in 2 ways:
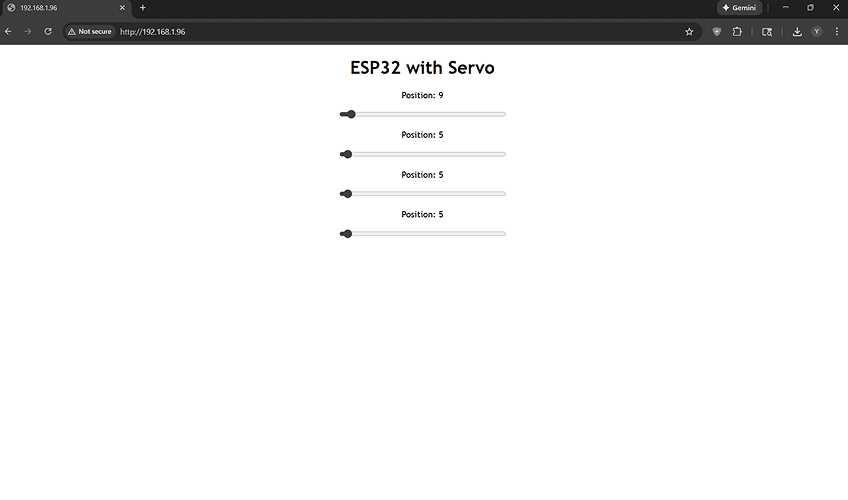
Remote control via HTML page
Predetermined movement via Python
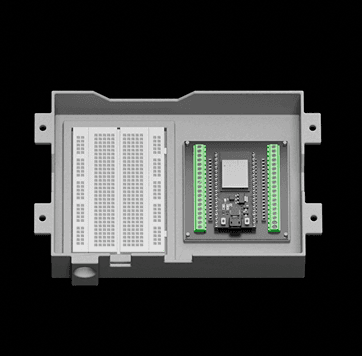
The linkages—designed in CAD software and fabricated via 3D printing—are paired with servo motors and an ESP32 microcontroller to enable remote control and pre-programmed movements. The robotic arm has 4 degrees of freedom and can be controlled through a web server hosted on the microcontroller.

what did I learn?
Tolerancing parts to integrate hardware such as servo motors, fasteners, and electrical components
Using a web server to communicate with an ESP32 microcontroller using Arduino IDE and Python
DFMA: designing parts that are optimized for 3D printing (strength + fabrication time) and ease of assembly.
01
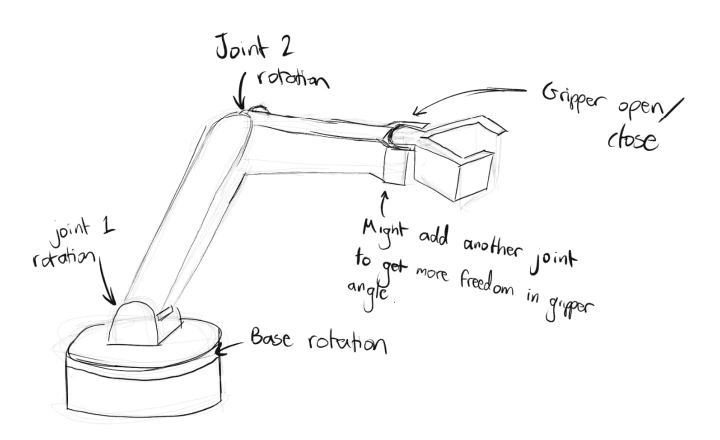
Concept Development
Fabrication


firmware
A combination of Arduino IDE and python scripts were used to code the firmware to enable remote control.

result
Final Design